Research area 01
Resilient Multi-Agent Autonomy
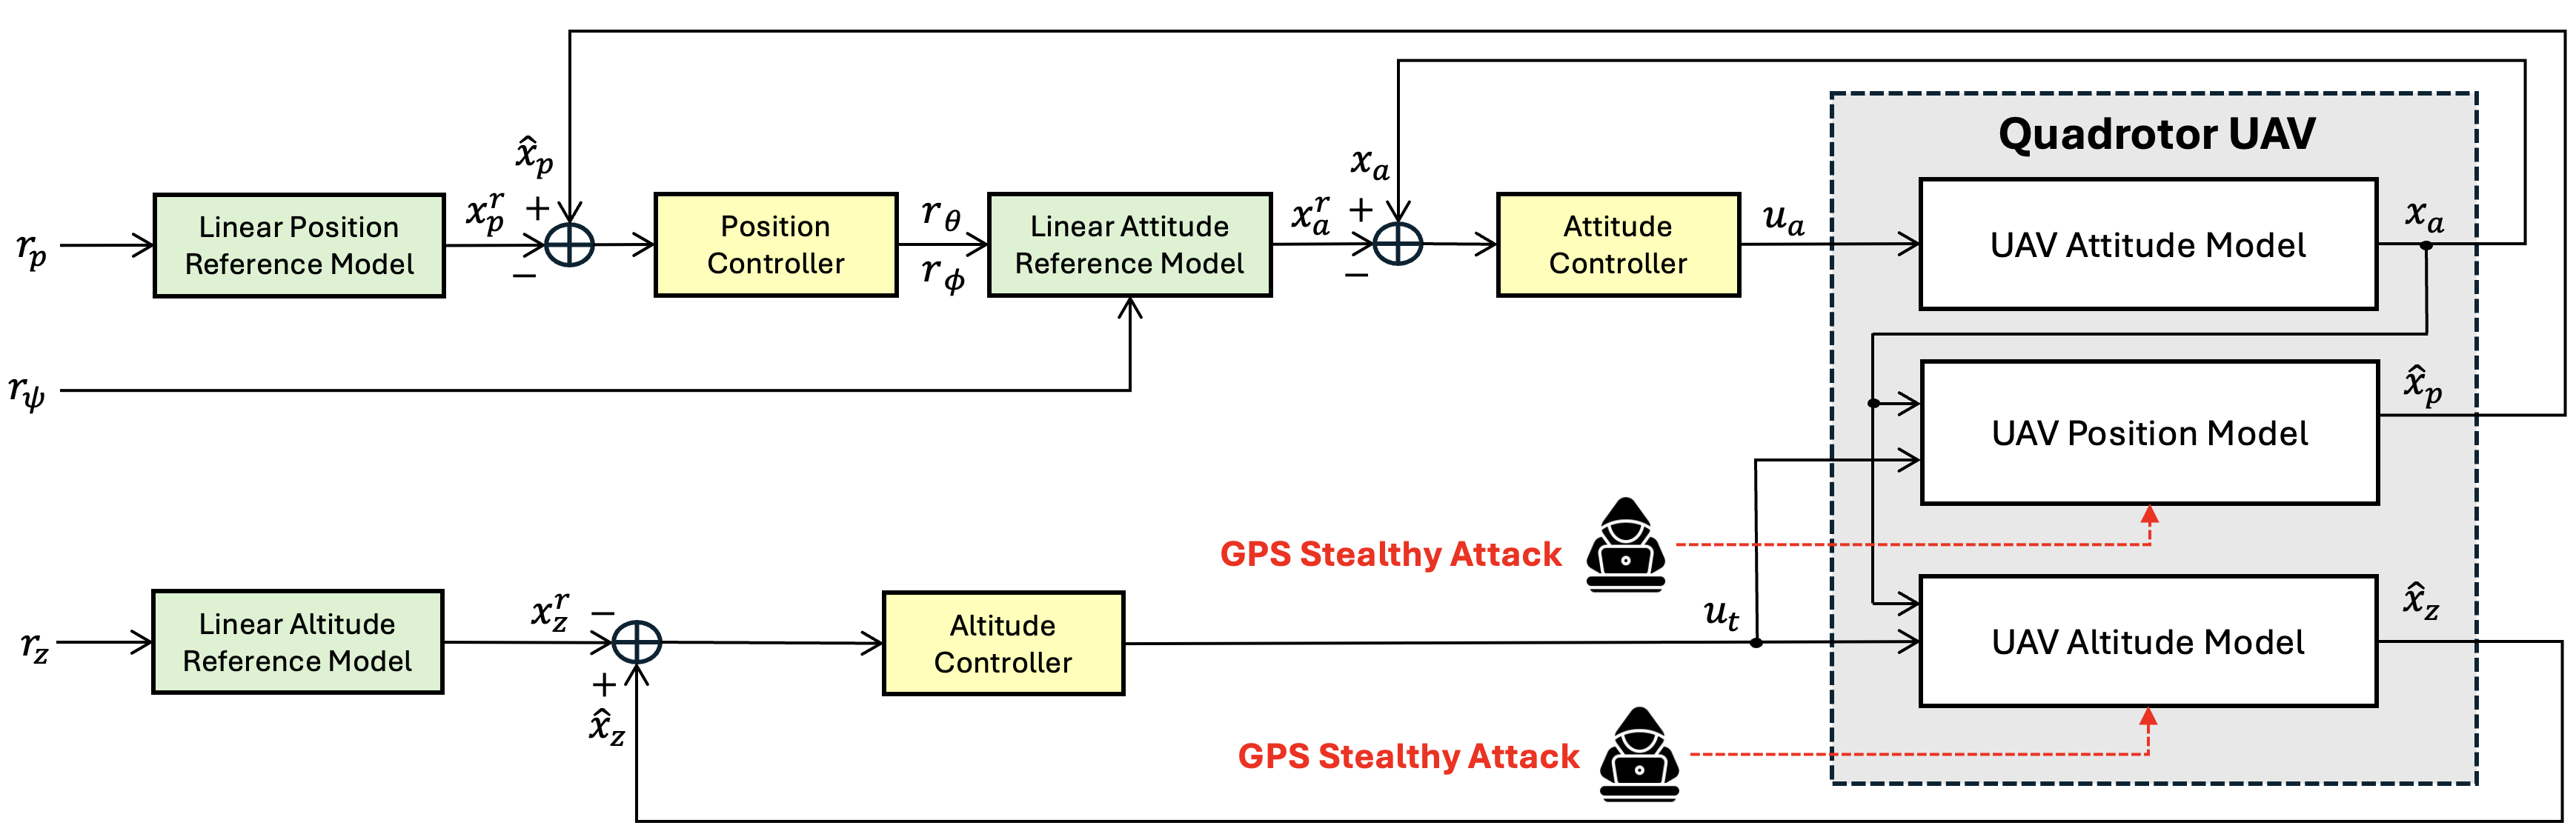
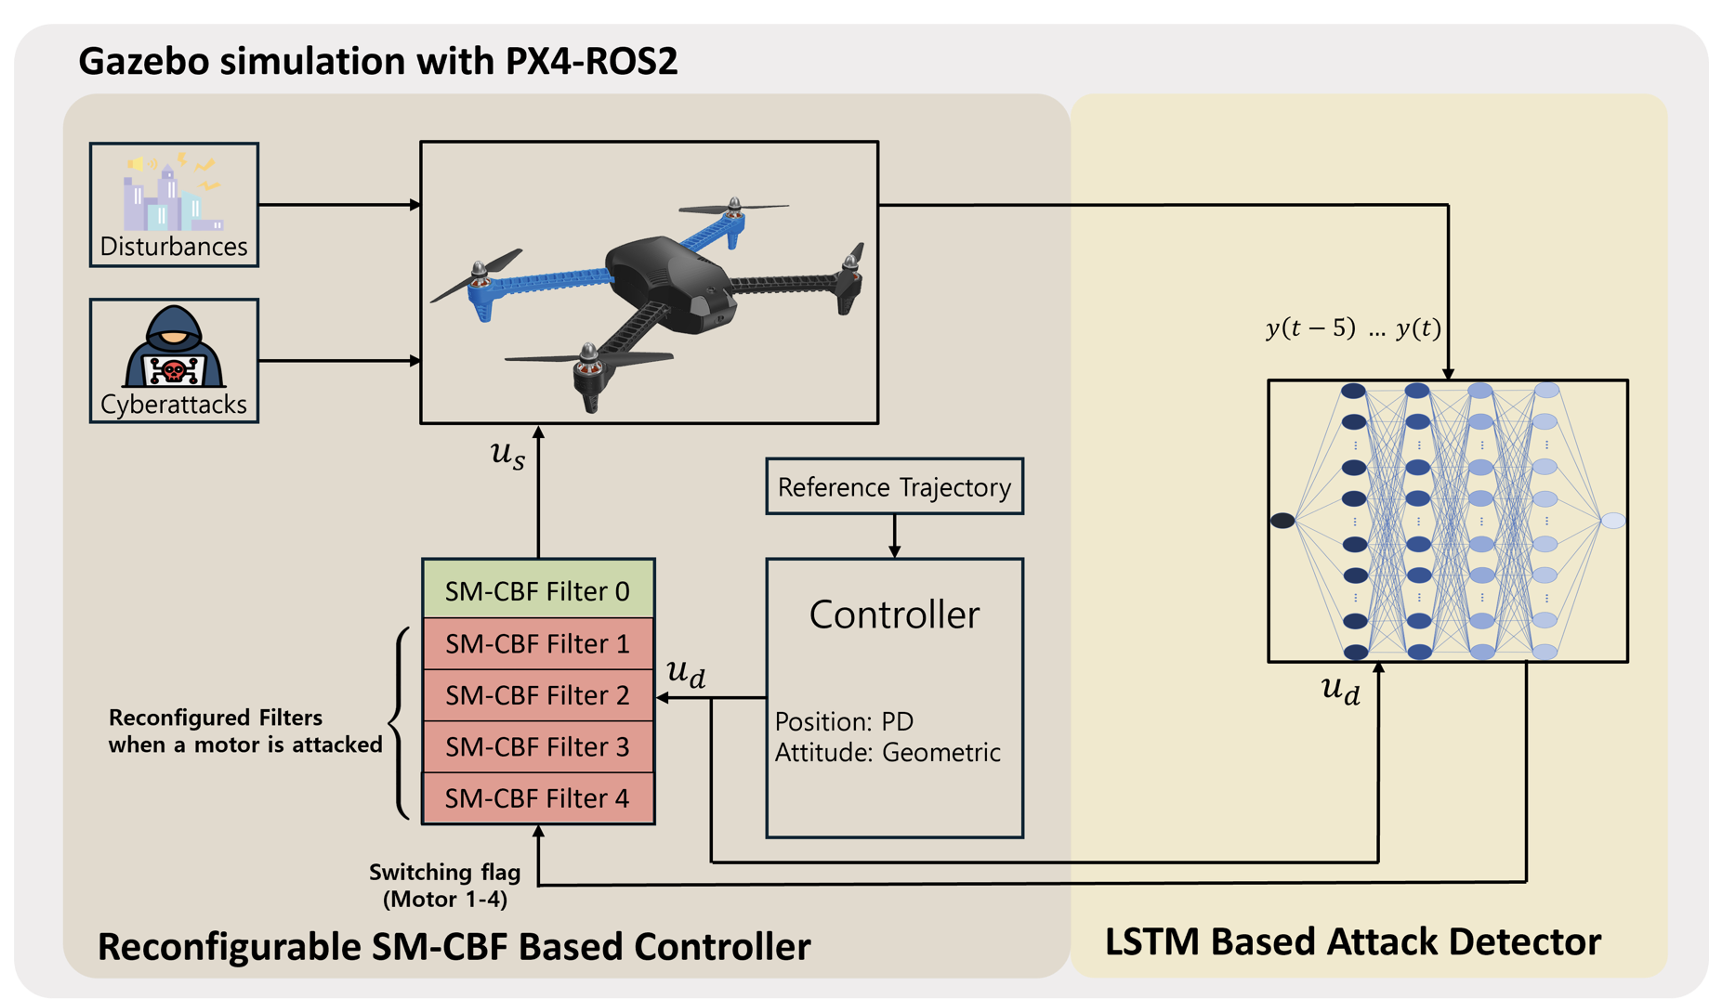
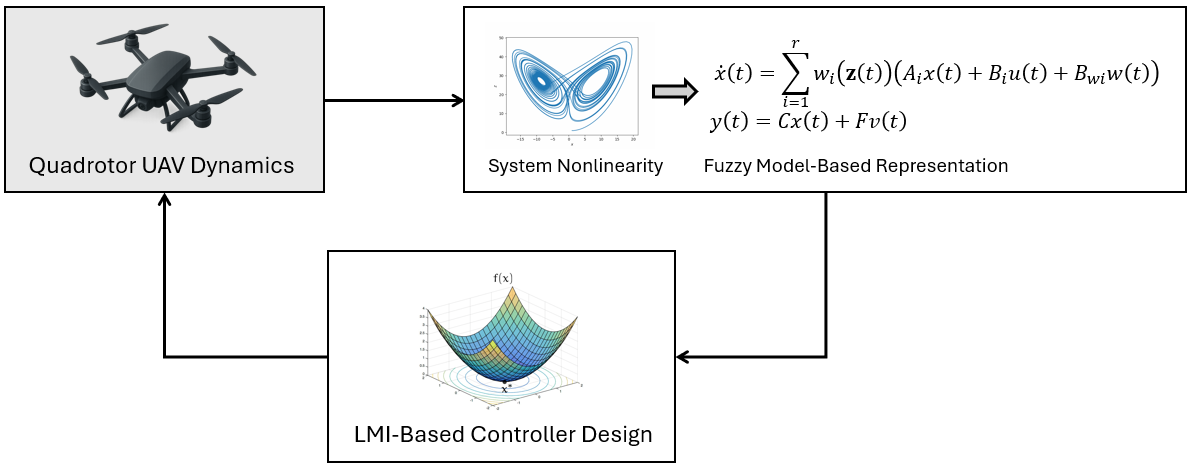
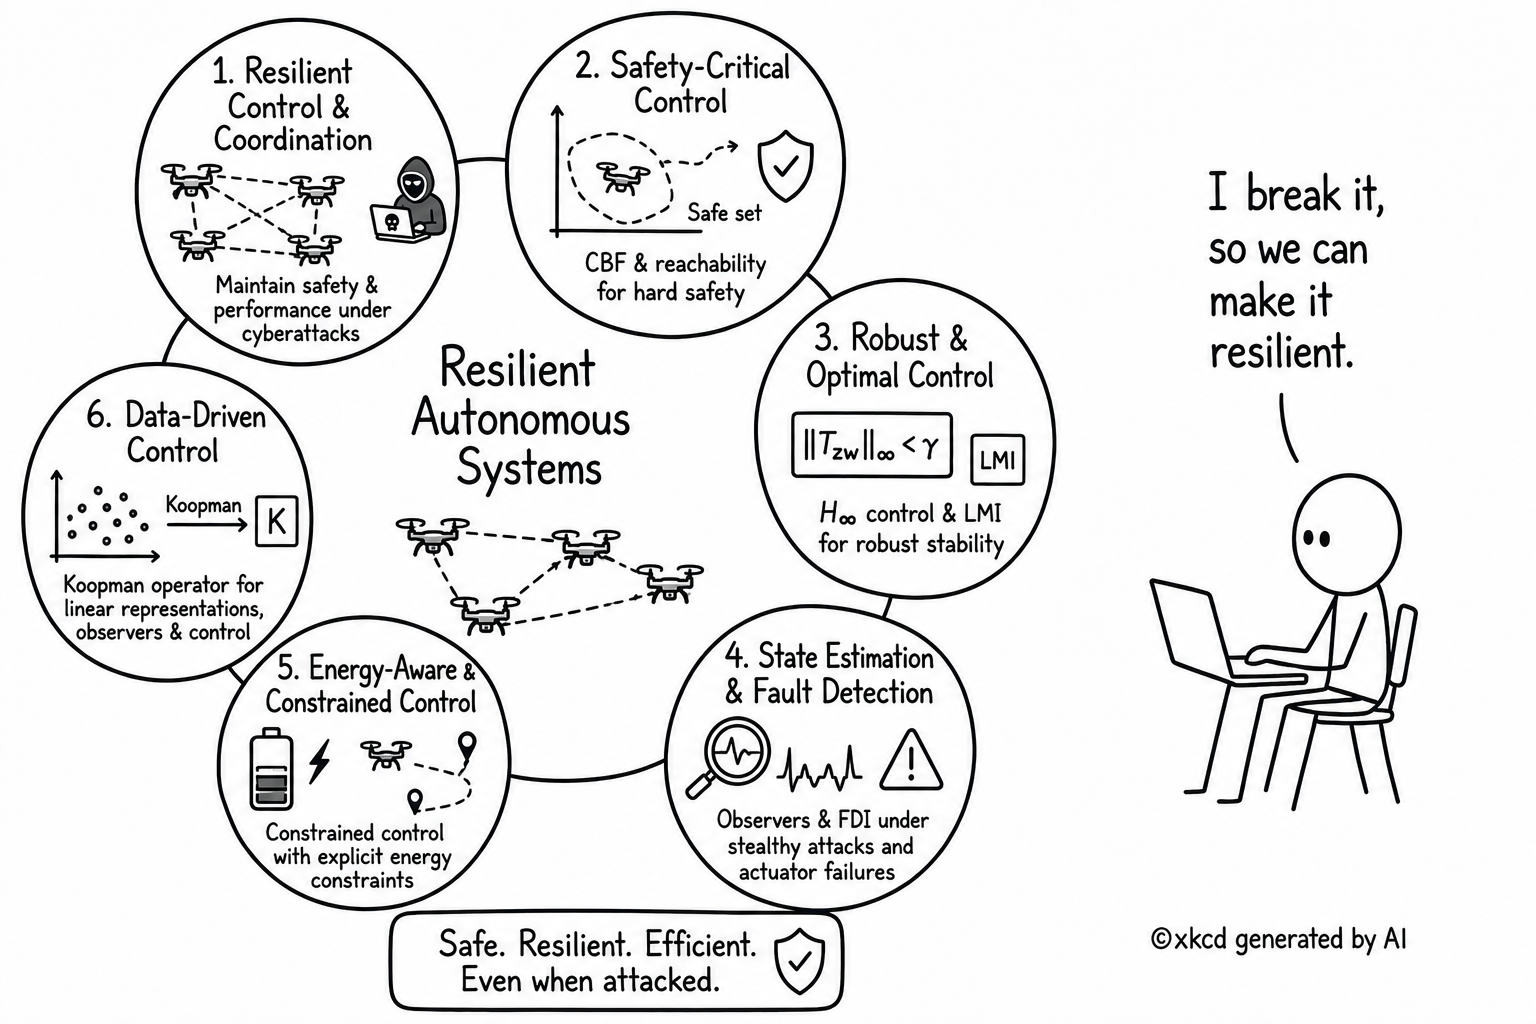
I develop control and estimation methods for cooperating autonomous vehicles under sensor attacks. My work combines reactive attack mitigation with proactive, reachability-based assessment of potential collision risks.
Research details & publications: Resilient Multi-Agent Autonomy
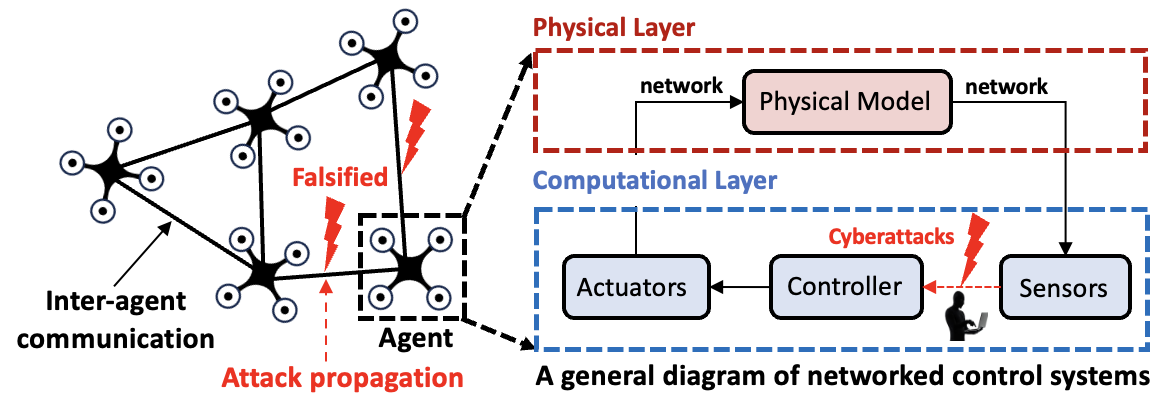
Multi-agent systems (MASs) have gained significant attention for their ability to solve complex engineering problems through cooperative decision-making. The primary objective in MAS operation is to achieve consensus among agents (e.g., UAVs, robots, and autonomous vehicles) to accomplish collaborative tasks. For example, urban air mobility (UAM) operations can be modeled as a MAS, where aerial vehicles coordinate their actions—such as formation control or velocity-matching consensus—by exchanging information (e.g., position and velocity) with neighboring agents. However, this communication-based structure also makes MASs inherently vulnerable to malicious threats, including cyberattacks, disturbances, and system faults. To address these challenges, my research focuses on developing advanced control and resilience mechanisms that enhance the safety and security of MASs operating in adversarial environments.
The following is the summary of our ongoing research:
Reactive Multi-Agent System Defense Strategy
Research Objective:
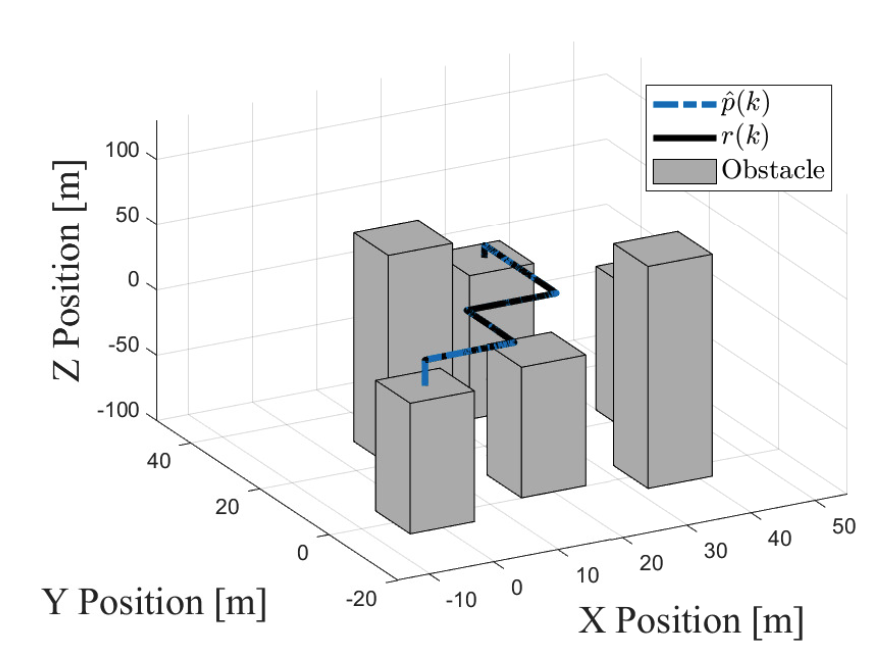
In this research topic, we aim to design resilient control and estimation algorithms that can directly mitigate the impact of adversities. To this end, we developed resilient sensor fusion and estimation algorithms that can filter out the malicious data/information embedded in measurement output. The following videos show the realistic UAM operation in Greater Atlanta with four AVs conducting reference tracking control with formation flight. The left video shows the off-nominal UAM operation with a high risk of collisions. However, the right video shows the resilient UAM operation using our proposed method with high-assured safety.
Publications:
- Sounghwan Hwang*, Minhyun Cho, and Inseok Hwang, " An Observer-Based Resilient Control Strategy for Leader-Follower Multi-Agent Systems Under False-Data-Injection Attacks ", 2024 Midwest Workshop in Control and Game Theory, April 27–28, 2024, Northwestern University, Illinois, USA.
- Sounghwan Hwang*, Minhyun Cho, Guanlin Wu, and Inseok Hwang, " Resilient Tracking Control For Leader-Follower Multi-Agent Systems Against Sinusoidal Sensor Attacks: An LMI-Based Framework ", IEEE Control Systems Letters (L-CSS), vol. 9, pp. 1123-1128, June 2025. (Also presented at the 64nd IEEE Conference on Decision and Control.)
Proactive Multi-Agent System Defense Strategy
Research Objective:
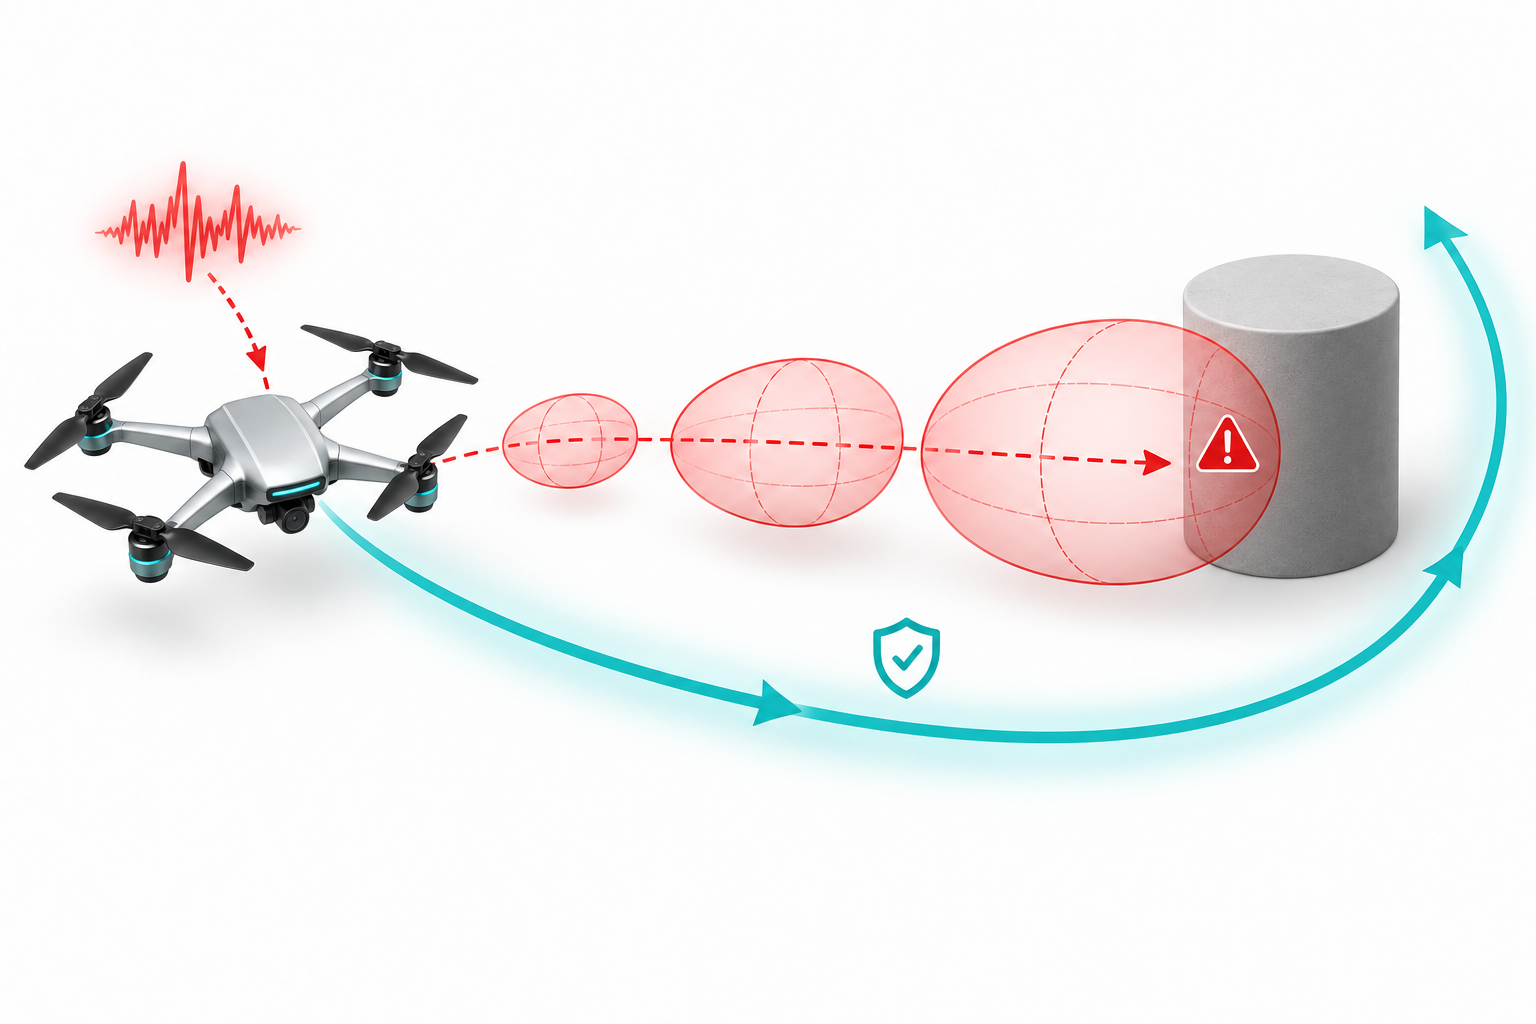
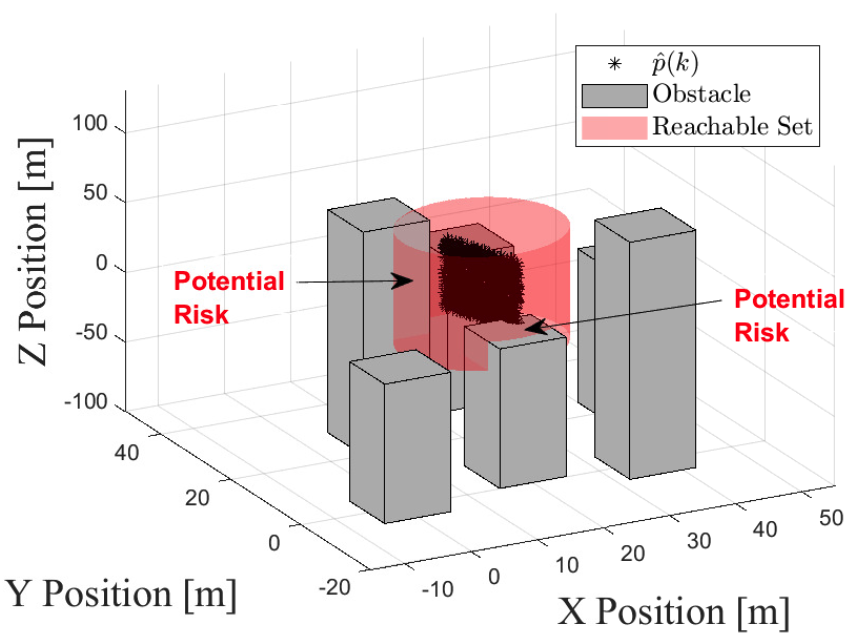
In this research topic, we focus on developing security metrics for multi-AVs that can measure the potential risk (e.g., collisions) by stealthy attacks. We specifically utilize an over-approximated ellipsoidal reachable set through the Lyapunov stability criterion. This reachable set (red-shaded ellipsoids) indicates the level of performance degradation (e.g., trajectory deviation) posed by attacks at certain future time steps. If there are overlaps between reachable sets, we can identify that associated AVs may have potential risks in terms of collisions during operation.
Publications:
- Sounghwan Hwang*, Minhyun Cho, Sungsoo Kim, and Inseok Hwang, " An LMI-Based Risk Assessment of Leader-Follower Multi-Agent System Under Stealthy Cyberattacks ", IEEE Control Systems Letters (L-CSS), vol. 7, pp. 2419–2424, 2023. (Also presented at the 62nd IEEE Conference on Decision and Control.)
- Minhyun Cho, Sounghwan Hwang*, and Inseok Hwang, " Risk Assessment of Multi-Agent System Under Denial-of-Service Cyberattacks Using Reachable Set Synthesis ", 2024 American Control Conference (ACC), pp. 1293–1298, Toronto, Canada, July 2024.
- Sounghwan Hwang*, Minhyun Cho, and Inseok Hwang, "Proactive Risk Assessment of Multi-Agent Transportation Systems via Reachability Analysis against Stealthy Attacks", Accepted as a book chapter to Advances in Transportation Cybersecurity and Resilience, World Scientific Publishing.