I apply control and estimation methods to aerial autonomy, electrified flight, heavy-duty vehicles, and precision motion systems. These projects connect my research with system modeling, controller development, and simulation.
Research projects
Aerial autonomyAug 2021 – Aug 2025
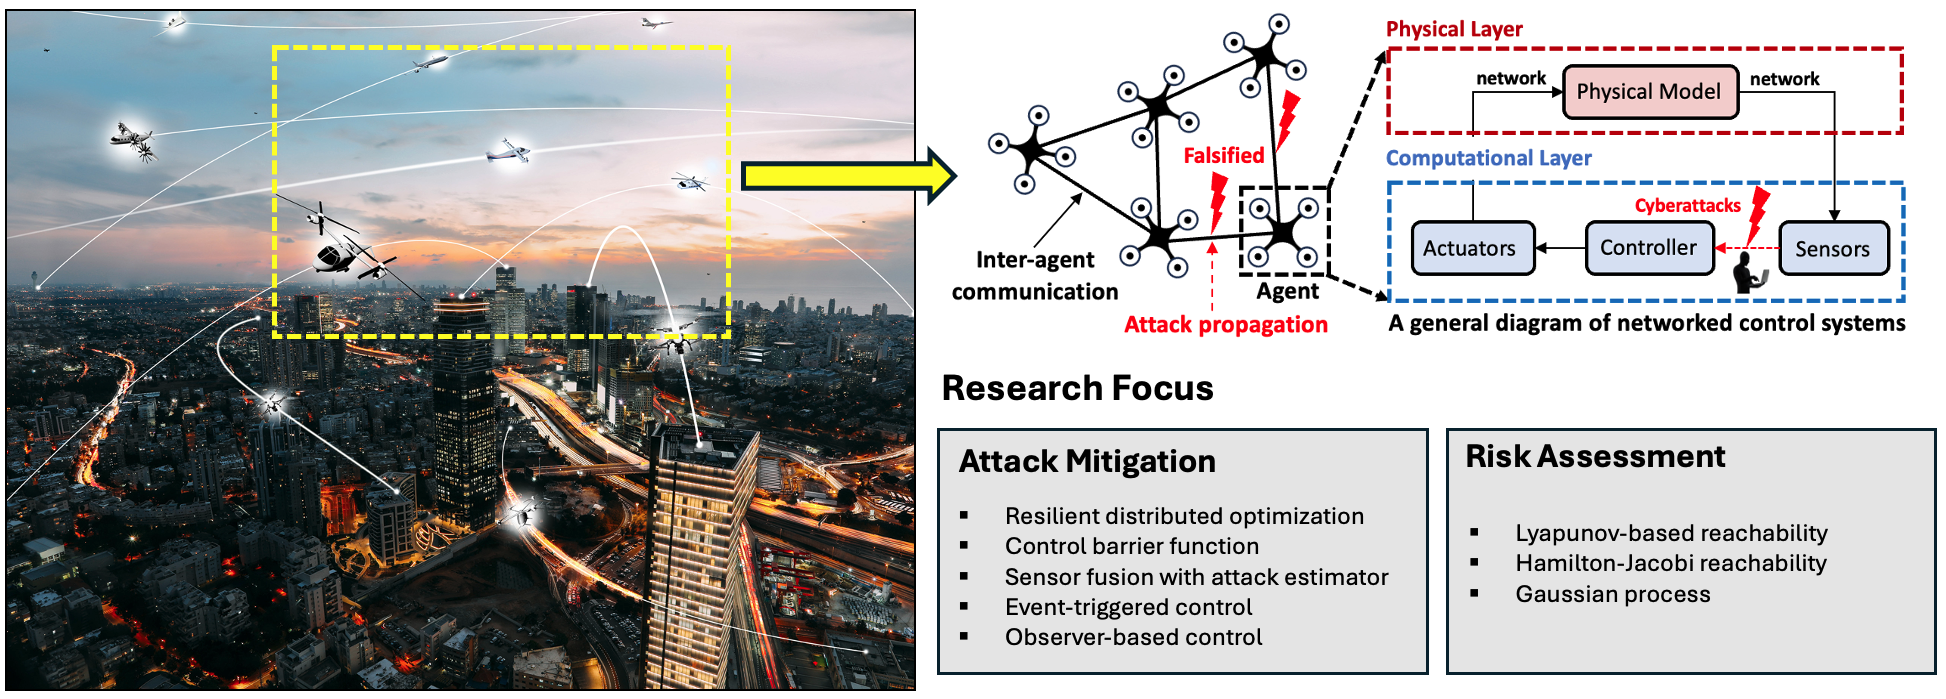
Secure Autonomy for Urban Air Mobility
Research sponsor: National Aeronautics and Space Administration (NASA)
My focus: Cyber threat management for cooperating aerial vehicles
ContributionAttack mitigation & risk assessment
Control-theoretic methods for multi-vehicle autonomy under cyberattacks and uncertainty.
Key contributions
Developed cyber threat management algorithms for multiple aerial vehicles.
Applied estimation and stability-based analysis to mitigate attacks and assess operational risk.
State estimation · Resilient control · Safety analysis
Cyber threat management for urban air mobility.
Project details & research framework: Secure Autonomy for Urban Air Mobility
Full project title: Secure and Safe Assured Autonomy for Urban Air Mobility
This project investigated vehicle-level control methods for safer and more secure urban air mobility (UAM). My work focused on cyber threat management for multiple aerial vehicles exposed to disturbances, model uncertainty, and cyberattacks.
I used control-theoretic tools, including Kalman filtering, control barrier functions, and Lyapunov stability analysis, to develop attack-mitigation and risk-assessment methods. The work connected cooperative flight control with the analysis of adversarial effects on vehicle operation.
Research sponsor: Ministry of Trade, Industry and Energy (MOTIE), Republic of Korea
My focus: Tilt-rotor modeling, flight control, and power-system simulation
Ongoing workLinking flight behavior to battery demand
An integrated view of aircraft dynamics, control commands, and electrical performance.
My work
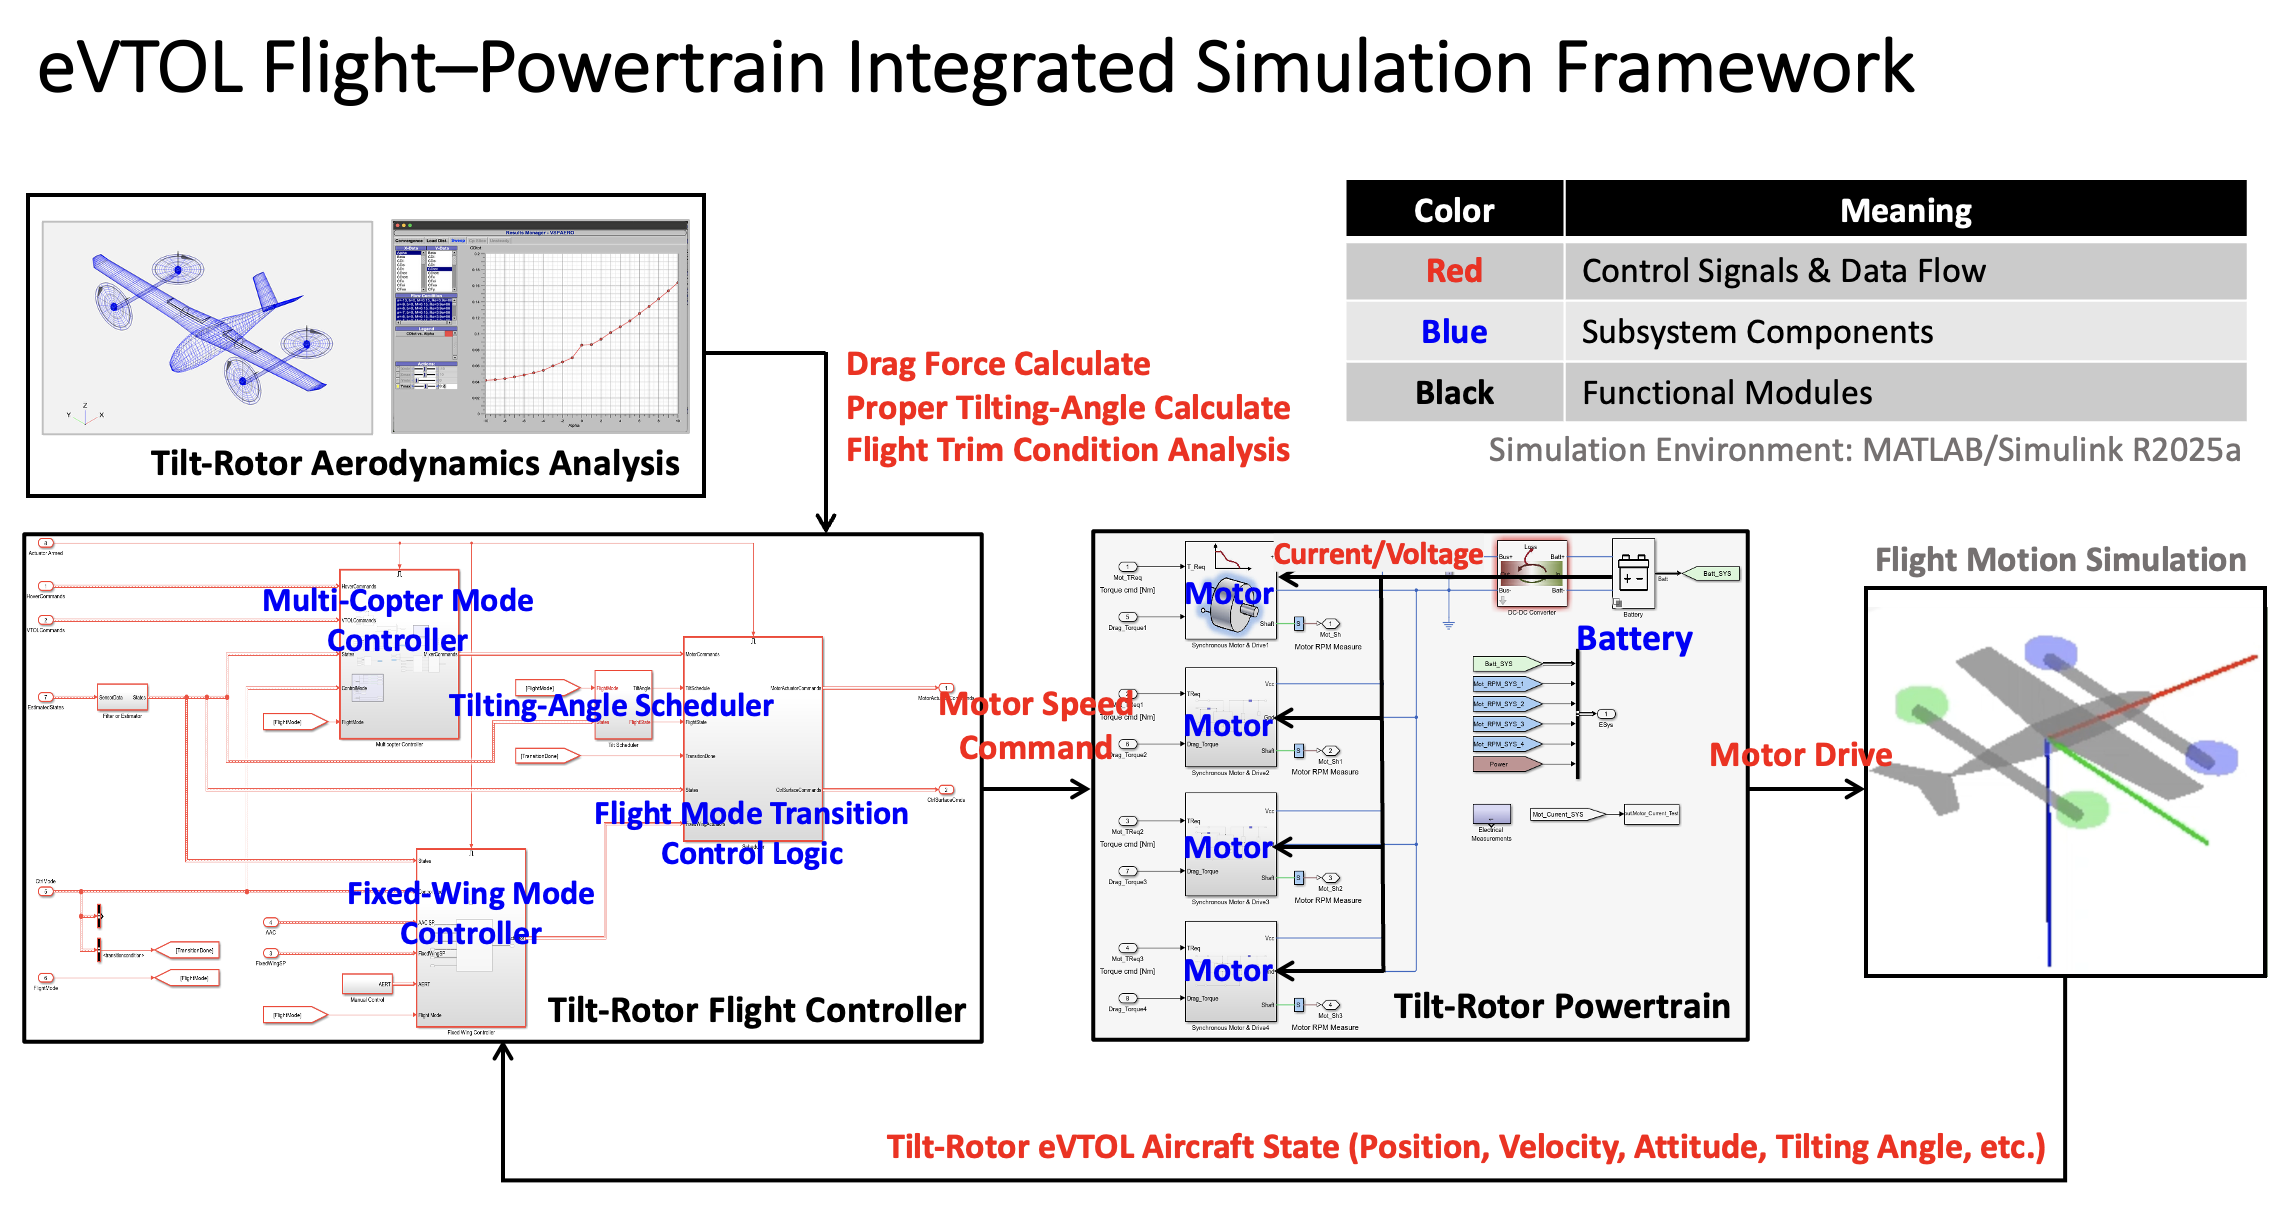
Integrate aerodynamic modeling, flight-controller design, and electric powertrain simulation.
Analyze energy consumption and stability across vertical flight, transition, and forward cruise.
Trim analysis · Robust control · MATLAB/Simulink
Integrated eVTOL flight and powertrain simulation.
Integrated flight & powertrain simulation
Flight Motion & Battery Performance
Simulation of tilt-rotor eVTOL flight motion and the corresponding battery response.
Flight motion and battery electrical response across a simulated flight profile.
Example application · Unreal Engine visualization
K-UAM Mission Example
As one example application of the simulator, flight-simulator outputs are integrated with Unreal Engine to visualize an eVTOL mission from Seoul Olympic Park to Bundang Central Park.
A 70-second visualization of this example mission. Use the player controls to pause or view full-screen.
Flight route
≈ 16.0 km · straight line
Seoul Olympic Park ↓ Straight-line simulation route Bundang Central Park
The interactive map loads here. You can also open either location using the links below.
Full project title: Development of Advanced Air Mobility Battery Management System
Within the advanced air mobility battery management project, my work centers on the design and analysis of tilt-rotor eVTOL aircraft. I combine aerodynamic modeling, power-system simulation, and control design to study flight from vertical takeoff through forward cruise and the return to hover.
The connection to battery management is the flight-to-powertrain model: flight maneuvers and controller commands determine motor demand, which in turn affects battery current, voltage, and energy consumption. Trim analysis, robust control, and battery-aware estimation support the study of mode transitions and mission-level electrical performance.
Integrated eVTOL flight and powertrain simulation.
Industry R&D
Heavy-duty vehiclesMay 2025 – Aug 2025
Predictive Eco-ACC for Class 8 Heavy-Duty Trucks
Company: Cummins Inc. · Cummins Technical Center
My role: Controls Research Engineer Intern · Connected and Intelligent Systems
Validated result2–5% improvement in fuel economy
Compared with an existing PID-based method that relies only on instantaneous information.
Key contributions
Led the design and implementation of real-time, MPC-based Eco-Adaptive Cruise Control for Class 8 semi-trucks.
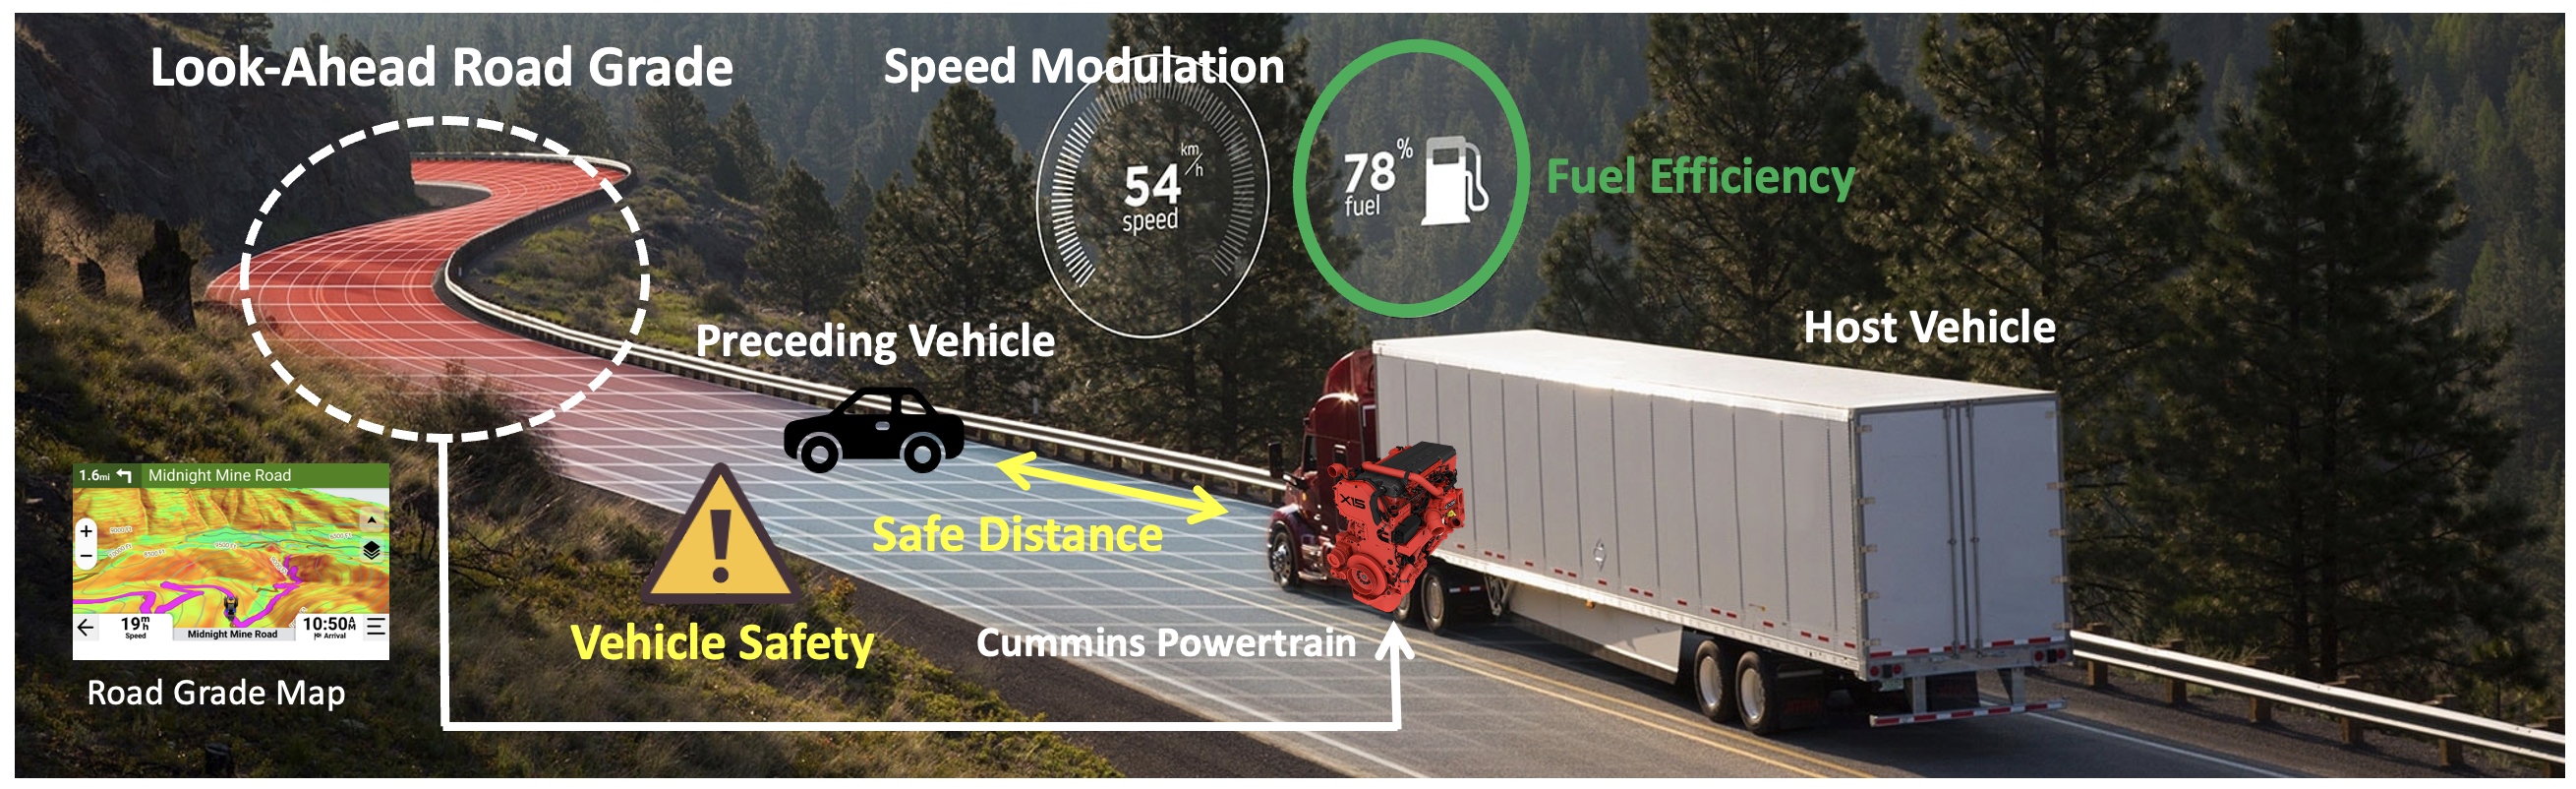
Incorporated road-grade preview and preceding-vehicle interactions to balance fuel efficiency with safety margins.
Model predictive control (MPC) · Road-grade preview · Safe following distance
Predictive speed control with road and traffic information.
Project details & evaluation: Predictive Eco-ACC for Heavy-Duty Trucks
Full project title: Design and Implementation of Eco-Adaptive Cruise Control for Class 8 Semi-Trucks
As a Controls Research Engineer Intern in Cummins’ Connected and Intelligent Systems group, I led the development of an Eco-Adaptive Cruise Control (Eco-ACC) system for Class 8 semi-trucks powered by Cummins power systems. The controller used model predictive control (MPC) to account for upcoming road grade and interactions with preceding vehicles.
Evaluation: MATLAB/Simulink-based simulations, using an existing PID-based method as the comparison baseline. The evaluated scenarios showed a 2–5% improvement in fuel economy while maintaining the specified safety margins.
Predictive speed control with road and traffic information.
Precision motion controlJun 2026 – Aug 2026
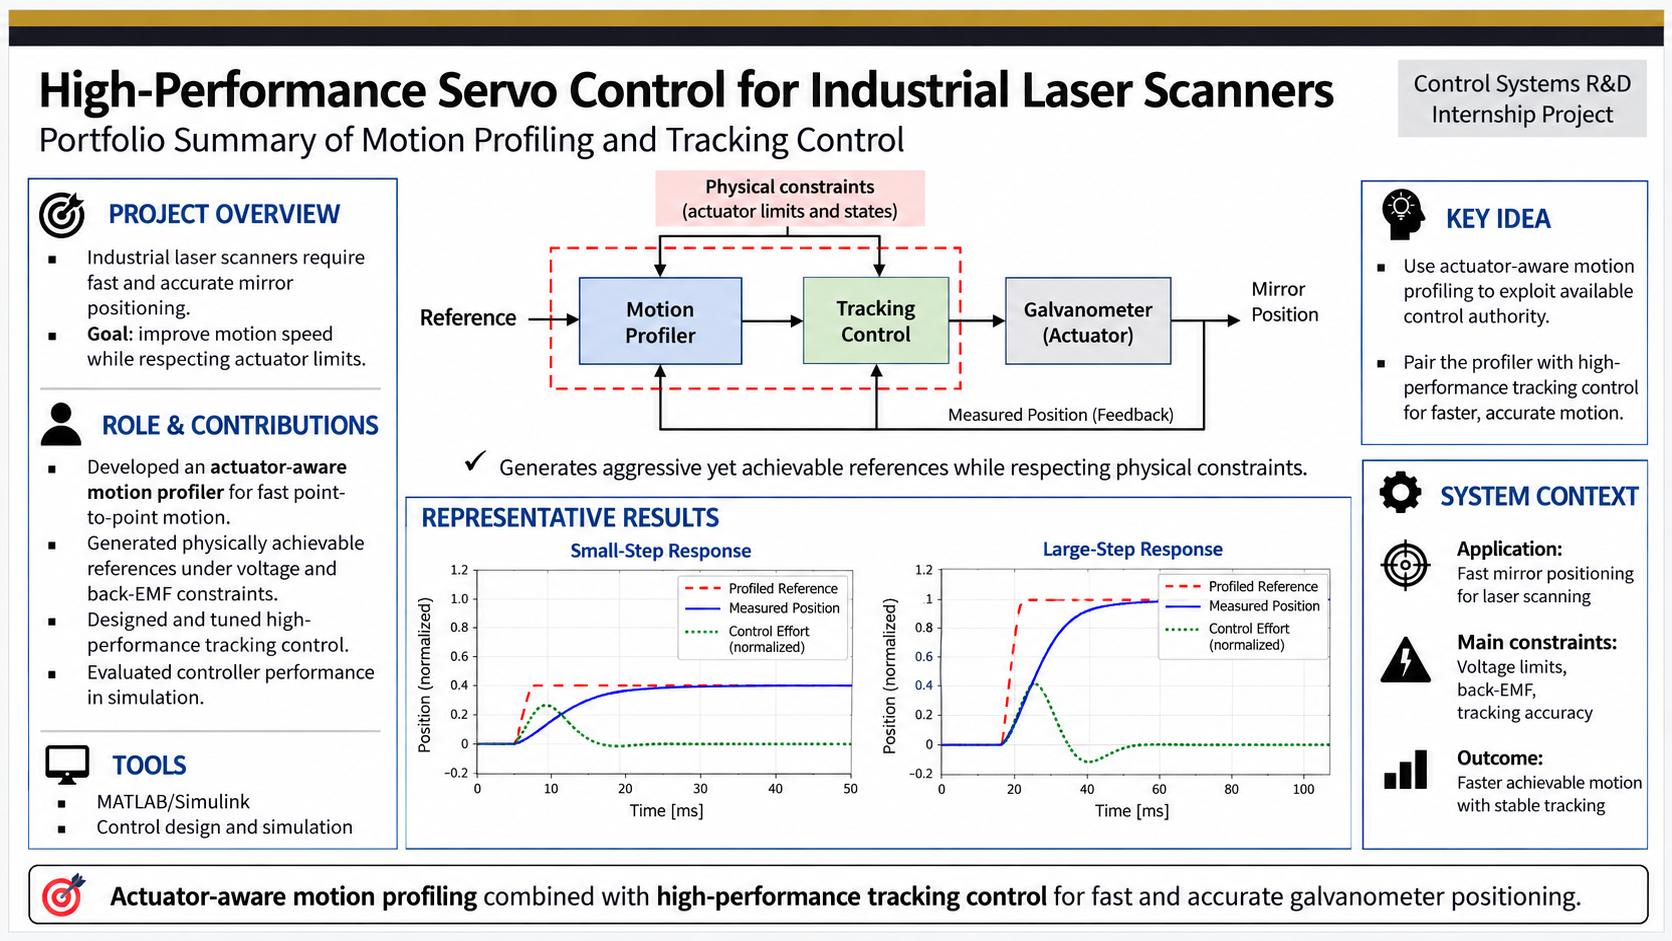
Actuator-Aware Control for Laser Scanners
Company: Pangolin Laser Systems · ScannerMAX Division
My role: Control Systems Servo R&D Intern · Servo Control Group
OutcomeNo amplitude-specific tuning
Real-time motion profiling that adapts to available actuator acceleration.
Key contributions
Developed a motion profiler and tracking controller for high-performance galvanometer scanners.
Combined bang-bang switching-curve control with a digital-twin voltage/current estimator to compute available acceleration at each control step.
Actuator-aware motion profiling and tracking control.
Project details & control architecture: Actuator-Aware Control for Laser Scanners
Full project title: Motion Profiler and Controller Design for High-Performance Galvanometer Scanners
In the Servo Control Group at Pangolin Laser Systems, I developed a real-time motion profiler and controller for galvanometer scanner systems. The design combined classical bang-bang switching-curve control with a digital-twin voltage/current estimator.
By computing available acceleration at each control step, the controller adapted the motion profile to actuator capabilities. This eliminated amplitude-specific tuning while enabling consistent full-voltage utilization across a wide range of motion amplitudes.
Actuator-aware motion profiling and tracking control.